Contact



CASE
Use Cases

Global
 Region

 Principles & vision
 Procurement
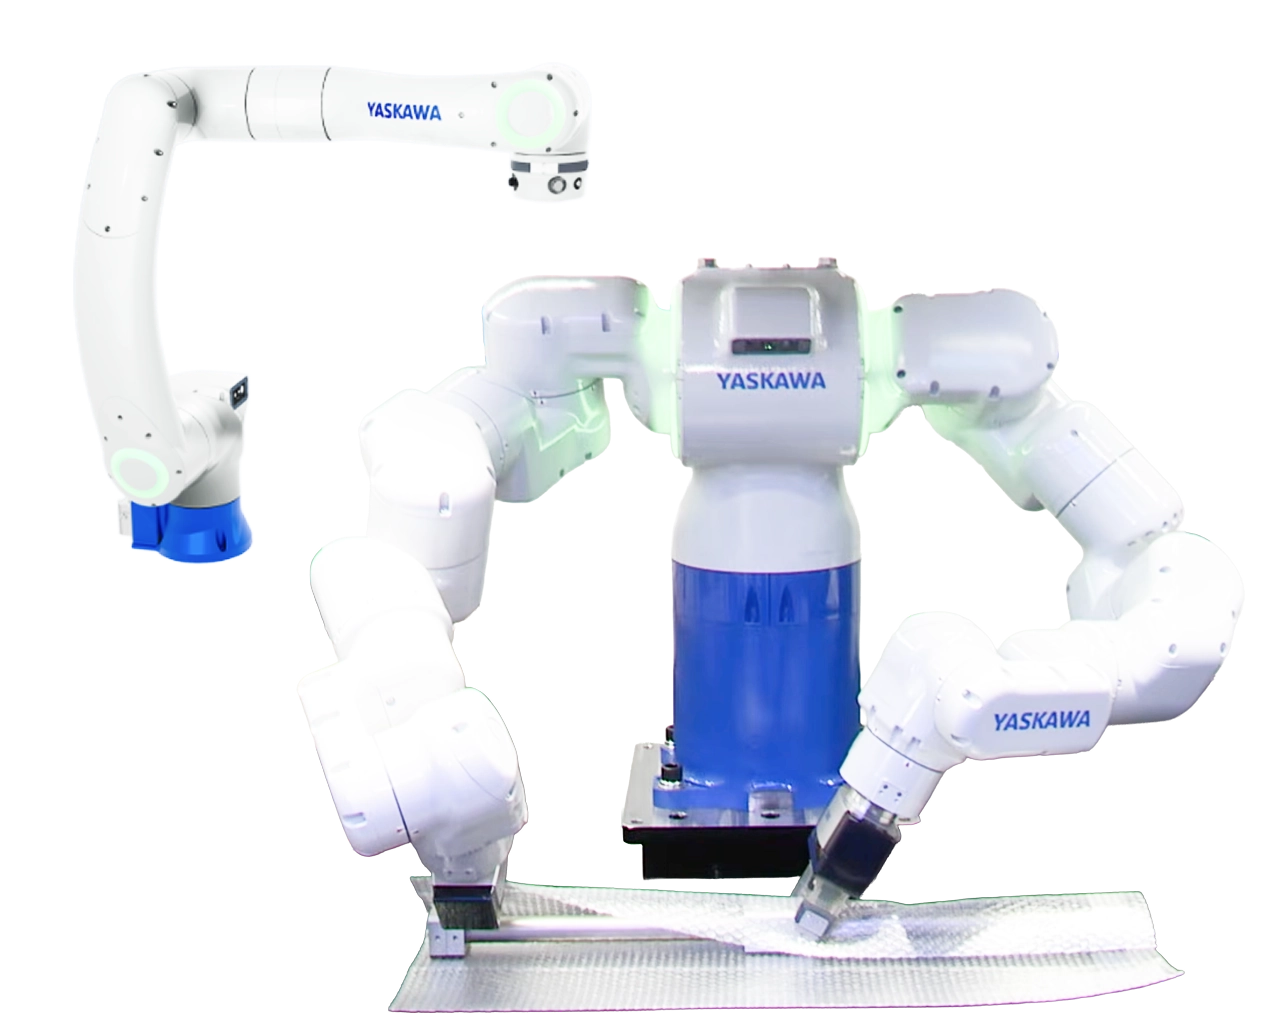
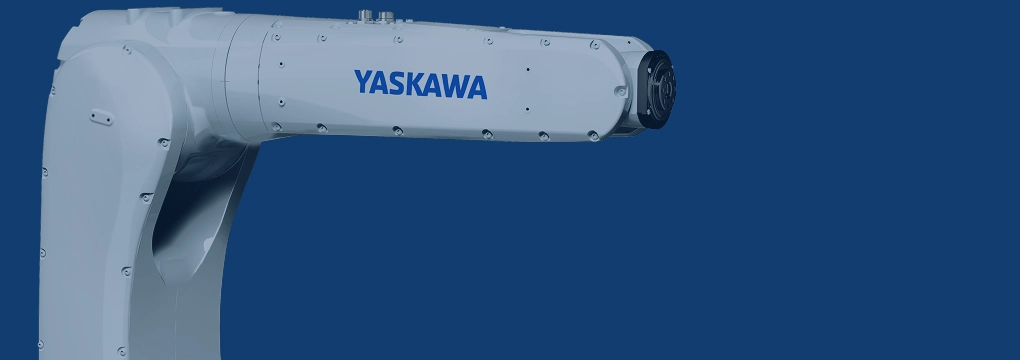
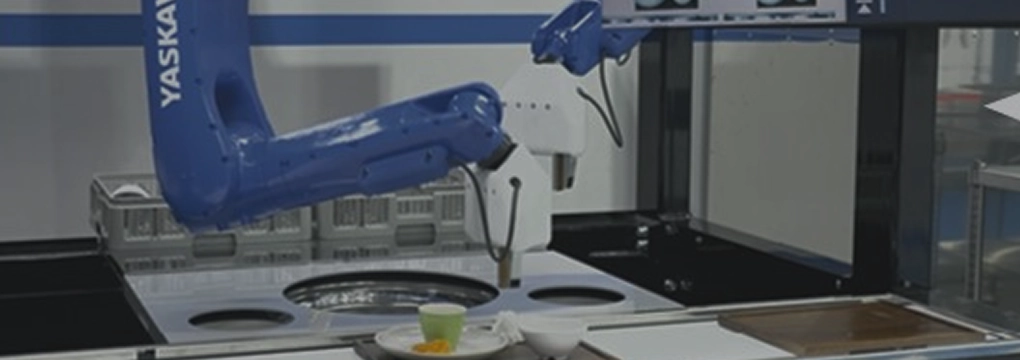
MOTOMAN NEXT is an industrial robot equipped with a GPU optimized for AI processing and an Autonomous Control Unit (ACU), enabling it to understand situations, make decisions, and act autonomously.
Through an open development environment, simulation technologies, and the utilization of operational data, Yaskawa continues to advance the automation of tasks that have traditionally depended on human labor.

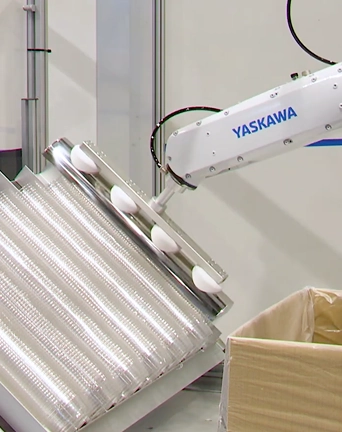
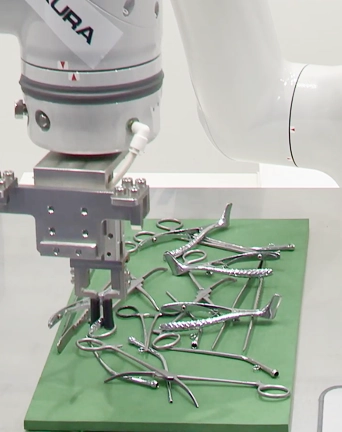
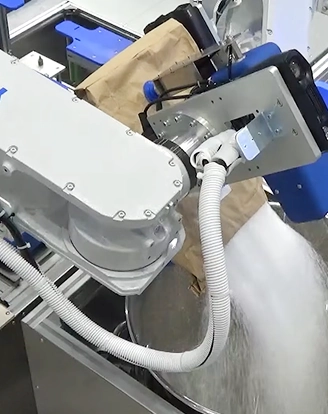
Tasks that previously required human labor can now be performed autonomously by robots. MOTOMAN NEXT is the first industrial robot to feature a built-in “brain.” This allows the robots to understand situations, make decisions, and act autonomously.
MOTOMAN NEXT is the first industrial robot to include a GPU as a standard component. GPUs were originally developed to process large amounts of visual data for games and video applications. They excel at processing large volumes of information quickly and efficiently. This makes them ideal for AI applications that analyze camera images and interpret situations.
The Autonomous Control Unit (ACU) is a system built around a GPU. In simple terms, the ACU acts as the robot’s brain.
The ACU enables the robot to recognize variations in object position and shape, as well as changes in the surrounding environment. Based on this information, it determines the best action and creates a task plan.
By combining AI-driven intelligence with Yaskawa’s long-established motion-control technologies, Yaskawa automates the tasks that previously required human skills.

MOTOMAN NEXT not only automates operations but also provides mechanisms that enable automation to expand more rapidly and broadly. Two key examples are described below.
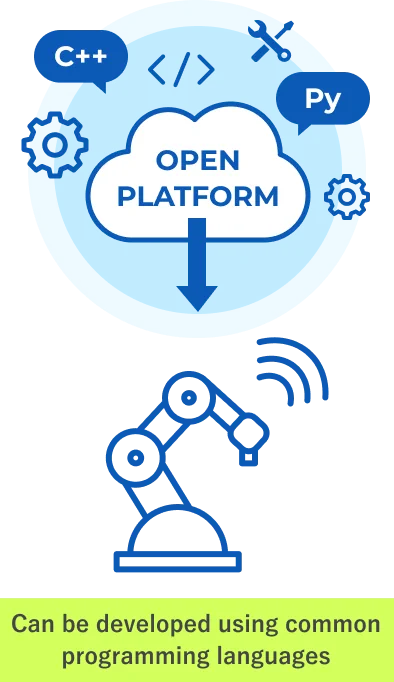
MOTOMAN NEXT is built on the concept of an Open Platform.
Rather than relying solely on Yaskawa, this framework enables open collaboration with companies and developers possessing expertise across diverse fields.
Traditional robots often required developers to learn a proprietary robot programming language. MOTOMAN NEXT can be developed using widely adopted programming languages such as Python and C++, allowing engineers around the world to develop applications more easily. More people can participate in development because developers do not need specialized robot language skills.
Combined with Yaskawa’s extensive robotics expertise and development support tools, this approach makes it easier to create solutions tailored to specific applications.
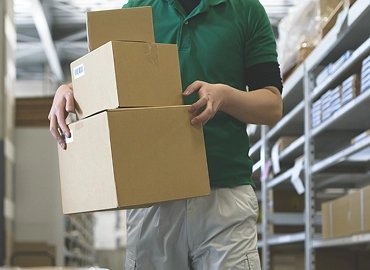
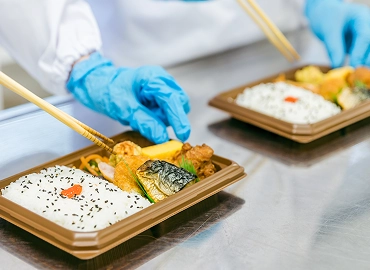
To deploy AI robots in the workplace and have them perform tasks traditionally done by humans, they must be trained in advance. They need to learn what environments and objects they will encounter and how to respond in different situations. It is also important to confirm that the robot can perform these actions correctly and safely.
Today, consumer needs are becoming more diverse, and more workplaces are producing a wider variety of products in smaller quantities. As a result, the types of objects robots handle and the conditions they face are becoming more complex. This requires training for a wider range of scenarios.
However, conducting such training and validation in physical environments requires significant time, space, labor, and cost. As a result, robots are not always fully prepared to deliver their best performance.
This is where a simulator comes in. A simulator is a virtual environment that recreates a real workplace inside computer and allows robots to experience a wide range of situations. Both training and performance validation can be carried out efficiently because many scenarios can be tested in a short time without using actual equipment or materials.
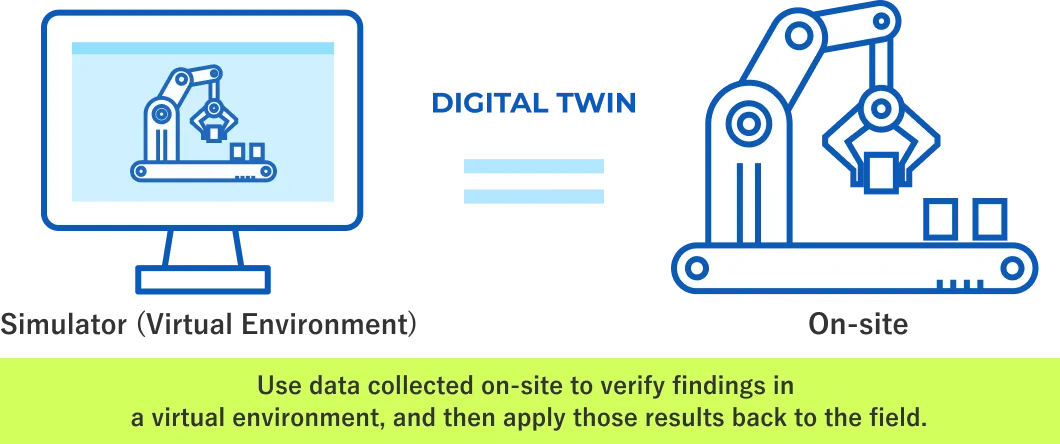
Recently, the concept of a digital twin has become increasingly important. A Digital Twin connects real workplace to a virtual environment through data. In other words, it creates creating a digital twin of the real workplace, allowing the same environment to be represented in a virtual space. Operational data collected from real environments is used within the virtual environment, and the resulting improvements are fed back into production. By continuously repeating this cycle, robot performance can be enhanced.
MOTOMAN NEXT combines high-speed responsiveness with precise execution in real-world operations. As a result, what is validated in the virtual environment can be reproduced with high accuracy in the actual workplace. This reduces trial and error while enabling safe and reliable operation. It also helps automate tasks that were previously difficult and supports environments where products and conditions change frequently.
For AI robots, the simulator serves as an essential training environment.
To further advance this approach, Yaskawa is integrating MOTOMAN NEXT with NVIDIA Isaac Sim™, a robotics simulator developed by NVIDIA. NVIDIA Isaac Sim accurately reproduces real-world physics, including object movement, weight, and collisions. This makes it possible to train and validate robots under conditions much closer to actual operations. The results obtained in the virtual environment can be reproduced on physical robots using Yaskawa’s control technologies, with high accuracy and rapid response.
This approach is known as Sim2Real, which stands for “Simulation to Reality.” The goal is not only to succeed in simulation but also to achieve reliable performance in real-world operations. Yaskawa’s strength lies in its ability to connect simulation and real-world execution with high accuracy.
Deploying MOTOMAN NEXT accelerates workplace digitalization and continuously accumulates high-quality operational data. To further improve AI-driven automation, this workplace data is essential.
With the introduction of MOTOMAN NEXT, processes and decisions that were previously hidden within manual work can be captured as digital data. By continuously collecting information such as task results, performance variations, motion histories, and environmental changes, operational conditions can be understood with greater accuracy.
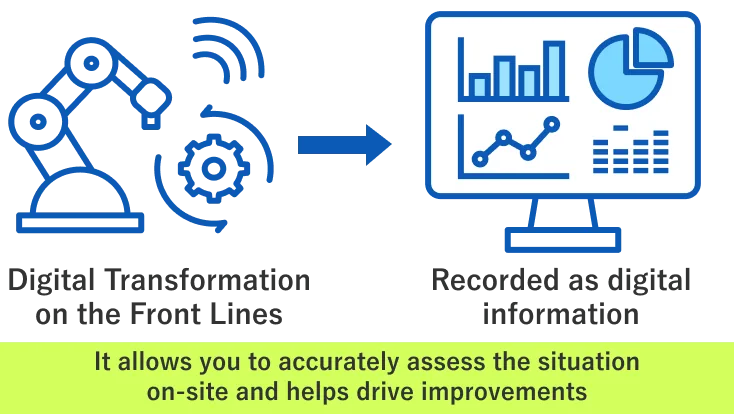
By utilizing this accumulated data, manufacturers can improve task accuracy, enhance efficiency, and adapt more easily to new operating conditions. As a result, they can continuously advance the level of automation. The data can also be used for training and verification in virtual environments. By using data from both the workplace and the simulator, robots can continuously improve their performance and discover better ways to operate.
In this way, automation evolves continuously through ongoing improvements driven by workplace, rather than being a one-time implementation. MOTOMAN NEXT provides a framework for continuously improving automation through workplace digitalization and data utilization.


Copyright © 2003‐2026 YASKAWA ELECTRIC CORPORATION.